 |
KiCad PCB EDA Suite
|
|
KiCad PCB EDA Suite
|
#include <shape_rect.h>
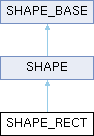
Public Member Functions | |
| SHAPE_RECT () | |
| Create an empty (0-sized) rectangle. | |
| SHAPE_RECT (const BOX2I &aBox) | |
| Create a rectangle defined by a BOX2. | |
| SHAPE_RECT (int aX0, int aY0, int aW, int aH) | |
| Create a rectangle defined by top-left corner (aX0, aY0), width aW and height aH. | |
| SHAPE_RECT (const VECTOR2I &aP0, int aW, int aH) | |
| Create a rectangle defined by top-left corner aP0, width aW and height aH. | |
| SHAPE_RECT (const VECTOR2I &aP0, const VECTOR2I &aP1) | |
| Create by two corners. | |
| SHAPE_RECT (const SHAPE_RECT &aOther) | |
| SHAPE * | Clone () const override |
| Return a dynamically allocated copy of the shape. | |
| const BOX2I | BBox (int aClearance=0) const override |
| Compute a bounding box of the shape, with a margin of aClearance a collision. | |
| SHAPE_RECT | GetInflated (int aOffset) const |
| Return a rectangle that is larger by aOffset in all directions, but still centered on the original rectangle. | |
| int | Diagonal () const |
| Return length of the diagonal of the rectangle. | |
| int | MajorDimension () const |
| int | MinorDimension () const |
| bool | Collide (const SHAPE *aShape, int aClearance, VECTOR2I *aActual) const override |
| Check if the boundary of shape (this) lies closer to the shape aShape than aClearance, indicating a collision. | |
| bool | Collide (const SHAPE *aShape, int aClearance=0, int *aActual=nullptr, VECTOR2I *aLocation=nullptr) const override |
| Check if the boundary of shape (this) lies closer to the shape aShape than aClearance, indicating a collision. | |
| bool | Collide (const SEG &aSeg, int aClearance=0, int *aActual=nullptr, VECTOR2I *aLocation=nullptr) const override |
| Check if the boundary of shape (this) lies closer to the segment aSeg than aClearance, indicating a collision. | |
| const VECTOR2I & | GetPosition () const |
| const VECTOR2I | GetSize () const |
| int | GetWidth () const override |
| int | GetHeight () const |
| int | GetRadius () const |
| void | SetRadius (int aRadius) |
| void | Move (const VECTOR2I &aVector) override |
| void | Rotate (const EDA_ANGLE &aAngle, const VECTOR2I &aCenter={ 0, 0 }) override |
| This function has limited utility for SHAPE_RECT as non-cartesian rotations will distort the rectangle. | |
| bool | IsSolid () const override |
| const SHAPE_LINE_CHAIN | Outline () const |
| virtual const std::string | Format (bool aCplusPlus=true) const override |
| void | TransformToPolygon (SHAPE_POLY_SET &aBuffer, int aError, ERROR_LOC aErrorLoc) const override |
| Fills a SHAPE_POLY_SET with a polygon representation of this shape. | |
| void | Normalize () |
| Ensure that the height and width are positive. | |
| int | GetClearance (const SHAPE *aOther) const |
| Return the actual minimum distance between two shapes. | |
| bool | IsNull () const |
| Return true if the shape is a null shape. | |
| virtual bool | Collide (const VECTOR2I &aP, int aClearance=0, int *aActual=nullptr, VECTOR2I *aLocation=nullptr) const |
| Check if the boundary of shape (this) lies closer to the point aP than aClearance, indicating a collision. | |
| virtual VECTOR2I | Centre () const |
| Compute a center-of-mass of the shape. | |
| virtual int | Distance (const VECTOR2I &aP) const |
| Returns the minimum distance from a given point to this shape. | |
| virtual SEG::ecoord | SquaredDistance (const VECTOR2I &aP, bool aOutlineOnly=false) const |
| bool | NearestPoints (const SHAPE *aOther, VECTOR2I &aPtThis, VECTOR2I &aPtOther) const |
| Return the two points that mark the closest distance between this shape and aOther. | |
| virtual bool | PointInside (const VECTOR2I &aPt, int aAccuracy=0, bool aUseBBoxCache=false) const |
| Check if point aP lies inside a closed shape. | |
| virtual VECTOR2I | GetStart () const |
| virtual VECTOR2I | GetEnd () const |
| virtual void | SetWidth (int aWidth) |
| virtual bool | Parse (std::stringstream &aStream) |
| FACET * | NewFacet () |
| SGNODE * | CalcShape (SGNODE *aParent, SGNODE *aColor, WRL1_ORDER aVertexOrder, float aCreaseLimit=0.74317, bool isVRML2=false) |
| SHAPE_TYPE | Type () const |
| Return the type of the shape. | |
| wxString | TypeName () const |
| virtual bool | HasIndexableSubshapes () const |
| virtual size_t | GetIndexableSubshapeCount () const |
| virtual void | GetIndexableSubshapes (std::vector< const SHAPE * > &aSubshapes) const |
Static Public Attributes | |
| static const int | MIN_PRECISION_IU = 4 |
| This is the minimum precision for all the points in a shape. | |
Protected Types | |
| typedef VECTOR2I::extended_type | ecoord |
Protected Attributes | |
| SHAPE_TYPE | m_type |
| type of our shape | |
Private Attributes | |
| VECTOR2I | m_p0 |
| Top-left corner. | |
| int | m_w |
| Width. | |
| int | m_h |
| Height. | |
| int | m_radius |
| Corner radius. | |
| std::list< FACET * > | facets |
Definition at line 34 of file shape_rect.h.
|
protectedinherited |
|
inline |
Create an empty (0-sized) rectangle.
Definition at line 40 of file shape_rect.h.
References m_h, m_radius, m_w, SH_RECT, and SHAPE::SHAPE().
Referenced by Clone(), GetInflated(), and SHAPE_RECT().
|
inline |
Create a rectangle defined by a BOX2.
Definition at line 50 of file shape_rect.h.
References GetHeight(), GetPosition(), GetWidth(), m_h, m_p0, m_radius, m_w, SH_RECT, and SHAPE::SHAPE().
|
inline |
Create a rectangle defined by top-left corner (aX0, aY0), width aW and height aH.
Definition at line 61 of file shape_rect.h.
References m_h, m_p0, m_radius, m_w, SH_RECT, and SHAPE::SHAPE().
|
inline |
Create a rectangle defined by top-left corner aP0, width aW and height aH.
Definition at line 72 of file shape_rect.h.
References m_h, m_p0, m_radius, m_w, SH_RECT, and SHAPE::SHAPE().
Create by two corners.
Definition at line 83 of file shape_rect.h.
References m_h, m_p0, m_radius, m_w, SH_RECT, and SHAPE::SHAPE().
|
inline |
Definition at line 91 of file shape_rect.h.
References m_h, m_p0, m_radius, m_w, SH_RECT, SHAPE::SHAPE(), and SHAPE_RECT().
|
inlineoverridevirtual |
Compute a bounding box of the shape, with a margin of aClearance a collision.
| aClearance | how much the bounding box is expanded wrs to the minimum enclosing rectangle for the shape. |
Implements SHAPE.
Definition at line 105 of file shape_rect.h.
|
inherited |
Definition at line 699 of file wrlfacet.cpp.
References IFSG_NODE::AddChildNode(), IFSG_INDEX::AddIndex(), IFSG_NODE::AddRefNode(), facets, IFSG_NODE::GetRawPtr(), S3D::GetSGNodeParent(), IFSG_FACESET::NewNode(), IFSG_SHAPE::NewNode(), IFSG_COLORS::SetColorList(), IFSG_COORDS::SetCoordsList(), IFSG_NORMALS::SetNormalList(), SGPOINT::x, SGPOINT::y, and SGPOINT::z.
Referenced by WRL1FACESET::TranslateToSG(), WRL2FACESET::TranslateToSG(), and X3DIFACESET::TranslateToSG().
|
inlinevirtualinherited |
Compute a center-of-mass of the shape.
Definition at line 242 of file shape.h.
References BBox(), and BOX2< Vec >::Centre().
Referenced by PCB_CONTROL::ApplyDesignBlockLayout(), PNS::TOPOLOGY::AssembleDiffPair(), BOOST_FIXTURE_TEST_CASE(), BOOST_FIXTURE_TEST_CASE(), BOOST_FIXTURE_TEST_CASE(), BOOST_FIXTURE_TEST_CASE(), BOOST_FIXTURE_TEST_CASE(), Collide(), PNS::HELPERS::PickSegment(), and DRC_TEST_PROVIDER_EDGE_CLEARANCE::resolveSilkDisposition().
|
inlineoverridevirtual |
Return a dynamically allocated copy of the shape.
| copy | of the shape |
Reimplemented from SHAPE.
Definition at line 99 of file shape_rect.h.
References SHAPE::SHAPE(), and SHAPE_RECT().
|
inlinevirtualinherited |
Check if the boundary of shape (this) lies closer to the point aP than aClearance, indicating a collision.
| [in] | aP | is the position to check for a collision. |
| aClearance | is the allowable tolerance of the collision comparison. | |
| [out] | aActual | an optional pointer to an int to store the actual distance in the event of a collision. |
| [out] | aLocation | an option pointer to a point to store a nearby location in the event of a collision. |
Reimplemented in SHAPE_ARC, SHAPE_LINE_CHAIN, SHAPE_LINE_CHAIN_BASE, SHAPE_POLY_SET, and SHAPE_SEGMENT.
Definition at line 181 of file shape.h.
References Collide().
Referenced by BOOST_AUTO_TEST_CASE(), DRC_RTREE::CheckColliding(), DRC_RTREE::CheckColliding(), FOOTPRINT::CheckShortingPads(), CN_ZONE_LAYER::Collide(), Collide(), SHAPE_ARC::Collide(), SHAPE_COMPOUND::Collide(), SHAPE_COMPOUND::Collide(), SHAPE_ELLIPSE::Collide(), SHAPE_POLY_SET::Collide(), SHAPE_RECT::Collide(), SHAPE_RECT::Collide(), SHAPE_SEGMENT::Collide(), SHAPE_SEGMENT::Collide(), collide(), PNS::ITEM::collideSimple(), PNS::TOPOLOGY::findLinesFromVia(), SCH_LINE::HitTest(), EDA_SHAPE::hitTest(), PCB_SELECTION_TOOL::hitTestDistance(), PNS::SHOVE::onCollidingVia(), PNS::SHOVE::onReverseCollidingVia(), PNS::HIT_VISITOR::operator()(), PNS::VIA::PushoutForce(), DRC_RTREE::QueryColliding(), DRC_RTREE::QueryColliding(), DRC_TEST_PROVIDER_SILK_CLEARANCE::Run(), KIGEOM::ShapeHitTest(), PNS::OPTIMIZER::smartPadsSingle(), DRC_TEST_PROVIDER_EDGE_CLEARANCE::testAgainstEdge(), DRC_TEST_PROVIDER_PHYSICAL_CLEARANCE::testItemAgainstItem(), DRC_TEST_PROVIDER_COPPER_CLEARANCE::testSingleLayerItemAgainstItem(), and DIALOG_TRACK_VIA_PROPERTIES::TransferDataFromWindow().
|
overridevirtual |
Check if the boundary of shape (this) lies closer to the segment aSeg than aClearance, indicating a collision.
| [in] | aSeg | is the segment to compare. |
| aClearance | is the allowable tolerance of the collision comparison. | |
| [out] | aActual | an optional pointer to an int to be updated with the actual distance int the event of a collision. |
| [out] | aLocation | an option pointer to a point to store a nearby location in the event of a collision. |
Implements SHAPE.
Definition at line 27 of file shape_rect.cpp.
References SEG::A, SEG::B, BBox(), SHAPE_LINE_CHAIN::Collide(), BOX2< Vec >::Contains(), VECTOR2< int32_t >::ECOORD_MAX, m_h, m_p0, m_radius, m_w, SEG::NearestPoint(), Outline(), SEG::Square(), and SEG::SquaredDistance().
|
inlineoverridevirtual |
Check if the boundary of shape (this) lies closer to the shape aShape than aClearance, indicating a collision.
| aShape | shape to check collision against | |
| aClearance | minimum clearance | |
| [out] | aActual | is the actual collision point |
Reimplemented from SHAPE.
Definition at line 147 of file shape_rect.h.
References SHAPE::Collide(), and SHAPE::SHAPE().
Referenced by Collide(), Collide(), SCH_SELECTION_TOOL::GuessSelectionCandidates(), and SCH_JUNCTION::HitTest().
|
inlineoverridevirtual |
Check if the boundary of shape (this) lies closer to the shape aShape than aClearance, indicating a collision.
| aShape | shape to check collision against | |
| aClearance | minimum clearance | |
| [out] | aActual | an optional pointer to an int to store the actual distance in the event of a collision. |
| [out] | aLocation | an option pointer to a point to store a nearby location in the event of a collision. |
Reimplemented from SHAPE.
Definition at line 152 of file shape_rect.h.
References SHAPE::Collide(), and SHAPE::SHAPE().
|
inline |
Return length of the diagonal of the rectangle.
Definition at line 132 of file shape_rect.h.
References VECTOR2< T >::EuclideanNorm(), m_h, and m_w.
|
virtualinherited |
Returns the minimum distance from a given point to this shape.
Always returns zero if the point is inside a closed shape and aOutlineOnly is false.
| aP | is the point to test |
Reimplemented in SHAPE_COMPOUND, and SHAPE_LINE_CHAIN.
Definition at line 105 of file shape.cpp.
References SquaredDistance().
|
overridevirtual |
|
inherited |
Return the actual minimum distance between two shapes.
| distance | in IU |
POLY_SETs contain a bunch of polygons that are triangulated. But there are way more triangles than necessary for collision detection. Triangles check three vertices each but for the outline, we only need one. These are also fractured, so we don't need to worry about holes
Definition at line 51 of file shape.cpp.
References SHAPE_POLY_SET::COutline(), SHAPE_BASE::GetIndexableSubshapeCount(), SHAPE_BASE::GetIndexableSubshapes(), SHAPE_POLY_SET::OutlineCount(), SH_POLY_SET, SHAPE(), and SHAPE_BASE::Type().
Referenced by BOOST_AUTO_TEST_CASE(), and BOOST_AUTO_TEST_CASE().
|
inlinevirtualinherited |
Reimplemented in SHAPE_ARC, and SHAPE_SEGMENT.
|
inline |
Definition at line 188 of file shape_rect.h.
References m_h.
Referenced by KIGFX::PCB_PAINTER::draw(), KIGEOM::GetPoint(), OUTSET_ROUTINE::ProcessItem(), and SHAPE_RECT().
|
inlinevirtualinherited |
Reimplemented in SHAPE_COMPOUND, and SHAPE_POLY_SET.
Definition at line 111 of file shape.h.
Referenced by SHAPE::GetClearance().
|
inlinevirtualinherited |
Reimplemented in SHAPE_COMPOUND, and SHAPE_POLY_SET.
Definition at line 113 of file shape.h.
Referenced by SHAPE_COMPOUND::AddShape(), and SHAPE::GetClearance().
|
inline |
Return a rectangle that is larger by aOffset in all directions, but still centered on the original rectangle.
Definition at line 116 of file shape_rect.h.
References m_h, m_p0, m_radius, m_w, and SHAPE_RECT().
Referenced by ROUNDRECT::OutsetFrom().
|
inline |
Definition at line 164 of file shape_rect.h.
References m_p0.
Referenced by CREEPAGE_GRAPH::Addshape(), PNS::BuildHullForPrimitiveShape(), Collide(), BOARD_ADAPTER::createPadWithMargin(), KIGFX::PCB_PAINTER::draw(), ROUTER_PREVIEW_ITEM::drawShape(), KIGEOM::GetPoint(), GetRectRoundedToGridOutwards(), NearestPoints(), OUTSET_ROUTINE::ProcessItem(), PNS::OPTIMIZER::rectBreakouts(), and SHAPE_RECT().
|
inline |
Definition at line 196 of file shape_rect.h.
References m_radius.
Referenced by BOOST_AUTO_TEST_CASE(), Collide(), Collide(), Collide(), Collide(), and Collide().
|
inline |
Definition at line 172 of file shape_rect.h.
Referenced by CREEPAGE_GRAPH::Addshape(), PNS::BuildHullForPrimitiveShape(), Collide(), BOARD_ADAPTER::createPadWithMargin(), KIGFX::PCB_PAINTER::draw(), ROUTER_PREVIEW_ITEM::drawShape(), GetRectRoundedToGridOutwards(), NearestPoints(), and PNS::OPTIMIZER::rectBreakouts().
|
inlinevirtualinherited |
Reimplemented in SHAPE_ARC, and SHAPE_SEGMENT.
Definition at line 296 of file shape.h.
Referenced by CADSTAR_PCB_ARCHIVE_LOADER::loadCoppers().
|
inlineoverridevirtual |
Reimplemented from SHAPE.
Definition at line 180 of file shape_rect.h.
References m_w.
Referenced by KIGFX::PCB_PAINTER::draw(), KIGEOM::GetPoint(), OUTSET_ROUTINE::ProcessItem(), and SHAPE_RECT().
|
inlinevirtualinherited |
Reimplemented in SHAPE_COMPOUND, and SHAPE_POLY_SET.
|
inlineinherited |
Return true if the shape is a null shape.
| true | if null :-) |
Definition at line 164 of file shape.h.
References SHAPE_BASE::m_type, and SH_NULL.
|
inlineoverridevirtual |
Implements SHAPE.
Definition at line 229 of file shape_rect.h.
|
inline |
Definition at line 137 of file shape_rect.h.
|
inline |
Definition at line 142 of file shape_rect.h.
|
inlineoverridevirtual |
|
inherited |
Return the two points that mark the closest distance between this shape and aOther.
If the shapes are overlapping, the points will be the same.
| aOther | the other shape to compare with | |
| [out] | aPtThis | the point on this shape closest to aOther |
| [out] | aPtOther | the point on aOther closest to this shape |
Definition at line 925 of file shape_nearest_points.cpp.
References nearestPoints(), and SHAPE().
Referenced by BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), BOOST_AUTO_TEST_CASE(), SHAPE_ARC::NearestPoints(), PAD::Recombine(), DRC_TEST_PROVIDER::reportTwoShapeGeometry(), and DRC_TEST_PROVIDER_ANNULAR_WIDTH::Run().
|
inherited |
Definition at line 691 of file wrlfacet.cpp.
References facets.
Referenced by WRL1FACESET::TranslateToSG(), WRL2FACESET::TranslateToSG(), and X3DIFACESET::TranslateToSG().
| void SHAPE_RECT::Normalize | ( | ) |
Ensure that the height and width are positive.
Definition at line 160 of file shape_rect.cpp.
| const SHAPE_LINE_CHAIN SHAPE_RECT::Outline | ( | ) | const |
Definition at line 148 of file shape_rect.cpp.
References SHAPE_ARC::DefaultAccuracyForPCB(), ERROR_INSIDE, SHAPE_POLY_SET::Outline(), and TransformToPolygon().
Referenced by Collide(), Collide(), Collide(), Collide(), Collide(), Collide(), Collide(), PAD::MergePrimitivesAsPolygon(), NearestPoints(), NearestPoints(), NearestPoints(), SHAPE_ARC::NearestPoints(), PCB_IO_EASYEDAPRO_PARSER::ParseBoard(), PCB_IO_EASYEDAPRO_V3_PARSER::ParseBoard(), BRDITEMS_PLOTTER::PlotShape(), DXF_PLOTTER::Rect(), PDF_PLOTTER::Rect(), PNG_PLOTTER::Rect(), PS_PLOTTER::Rect(), and SVG_PLOTTER::Rect().
|
virtualinherited |
Reimplemented in SHAPE_LINE_CHAIN, and SHAPE_POLY_SET.
|
virtualinherited |
Check if point aP lies inside a closed shape.
Always returns false if this shape is not closed.
| aPt | point to check. |
| aAccuracy | is the allowable tolerance of the cheack. |
| aUseBBoxCache | gives better performance if the bounding box caches have been generated. |
Reimplemented in SHAPE_ELLIPSE, SHAPE_LINE_CHAIN, SHAPE_LINE_CHAIN_BASE, and SHAPE_POLY_SET.
Definition at line 123 of file shape.cpp.
References SHAPE_POLY_SET::COutline(), ERROR_INSIDE, SHAPE_POLY_SET::OutlineCount(), SHAPE_LINE_CHAIN::PointInside(), and TransformToPolygon().
|
inlineoverridevirtual |
This function has limited utility for SHAPE_RECT as non-cartesian rotations will distort the rectangle.
If you might need to handle non-90° rotations then the SHAPE_RECT should first be converted to a SHAPE_SIMPLE which can then be free-rotated.
Implements SHAPE.
Definition at line 216 of file shape_rect.h.
|
inline |
Definition at line 201 of file shape_rect.h.
References m_radius.
Referenced by BOOST_AUTO_TEST_CASE(), BRDITEMS_PLOTTER::PlotShape(), DXF_PLOTTER::Rect(), PDF_PLOTTER::Rect(), PNG_PLOTTER::Rect(), PS_PLOTTER::Rect(), and SVG_PLOTTER::Rect().
|
inlinevirtualinherited |
Reimplemented in SHAPE_ARC, SHAPE_LINE_CHAIN, and SHAPE_SEGMENT.
|
virtualinherited |
Reimplemented in SHAPE_ELLIPSE, SHAPE_LINE_CHAIN_BASE, and SHAPE_POLY_SET.
Definition at line 111 of file shape.cpp.
References SHAPE_POLY_SET::COutline(), VECTOR2< int32_t >::ECOORD_MAX, ERROR_INSIDE, SHAPE_POLY_SET::OutlineCount(), SHAPE_LINE_CHAIN_BASE::SquaredDistance(), and TransformToPolygon().
Referenced by Distance(), and ROUTER_TOOL::InlineDrag().
|
overridevirtual |
Fills a SHAPE_POLY_SET with a polygon representation of this shape.
| [out] | aBuffer | will be filled with the polygonal representation of this shape. |
| aError | controls the maximum allowed deviation when converting rounded shapes to segments | |
| aErrorLoc | controls where the error is placed when approximating rounded shapes |
Implements SHAPE.
Definition at line 128 of file shape_rect.cpp.
References SHAPE_LINE_CHAIN::Append(), m_h, m_p0, m_radius, m_w, SHAPE_POLY_SET::NewOutline(), SHAPE_POLY_SET::Outline(), SHAPE_LINE_CHAIN::SetClosed(), and ROUNDRECT::TransformToPolygon().
Referenced by Outline().
|
inlineinherited |
Return the type of the shape.
| the | type |
Definition at line 96 of file shape.h.
References m_type.
Referenced by CREEPAGE_GRAPH::Addshape(), PNS::DP_GATEWAYS::BuildFromPrimitivePair(), PNS::BuildHullForPrimitiveShape(), PNS_LOG_VIEWER_FRAME::buildListTree(), Collide(), SHAPE_POLY_SET::Collide(), collideShapes(), collideSingleShapes(), comparePnsItems(), PNS::OPTIMIZER::computeBreakouts(), ROUTER_PREVIEW_ITEM::drawShape(), PNS_LOG_VIEWER_FRAME::drawSimpleShape(), EDA_SHAPE::EDA_SHAPE(), PNS::LOGGER::formatShapeAsJSON(), SHAPE::GetClearance(), nearestPoints(), nearestPointsSingleShapes(), DRC_RTREE::QueryColliding(), DRC_TEST_PROVIDER_EDGE_CLEARANCE::resolveSilkDisposition(), STROKE_PARAMS::Stroke(), and SHAPE_FILE_IO::Write().
|
inlineinherited |
|
privateinherited |
Definition at line 140 of file wrlfacet.h.
Referenced by CalcShape(), and NewFacet().
|
private |
Height.
Definition at line 250 of file shape_rect.h.
Referenced by BBox(), Collide(), Diagonal(), Format(), GetHeight(), GetInflated(), GetSize(), MajorDimension(), MinorDimension(), Normalize(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), and TransformToPolygon().
|
private |
Top-left corner.
Definition at line 248 of file shape_rect.h.
Referenced by BBox(), Collide(), Format(), GetInflated(), GetPosition(), Move(), Normalize(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), and TransformToPolygon().
|
private |
Corner radius.
Definition at line 251 of file shape_rect.h.
Referenced by Collide(), Format(), GetInflated(), GetRadius(), SetRadius(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), and TransformToPolygon().
|
protectedinherited |
type of our shape
Definition at line 117 of file shape.h.
Referenced by SHAPE::Format(), SHAPE::IsNull(), SHAPE_BASE(), Type(), and TypeName().
|
private |
Width.
Definition at line 249 of file shape_rect.h.
Referenced by BBox(), Collide(), Diagonal(), Format(), GetInflated(), GetSize(), GetWidth(), MajorDimension(), MinorDimension(), Normalize(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), SHAPE_RECT(), and TransformToPolygon().
|
staticinherited |
This is the minimum precision for all the points in a shape.
Definition at line 129 of file shape.h.
Referenced by DIRECTION_45::BuildInitialTrace(), CompareLength(), CIRCLE::Contains(), EDIT_TOOL::FilletTracks(), SHAPE_ELLIPSE::Intersect(), CIRCLE::IntersectLine(), and LINE_FILLET_ROUTINE::ProcessLinePair().
 1.13.2